Video 1. Human Walking with Exoskeleton
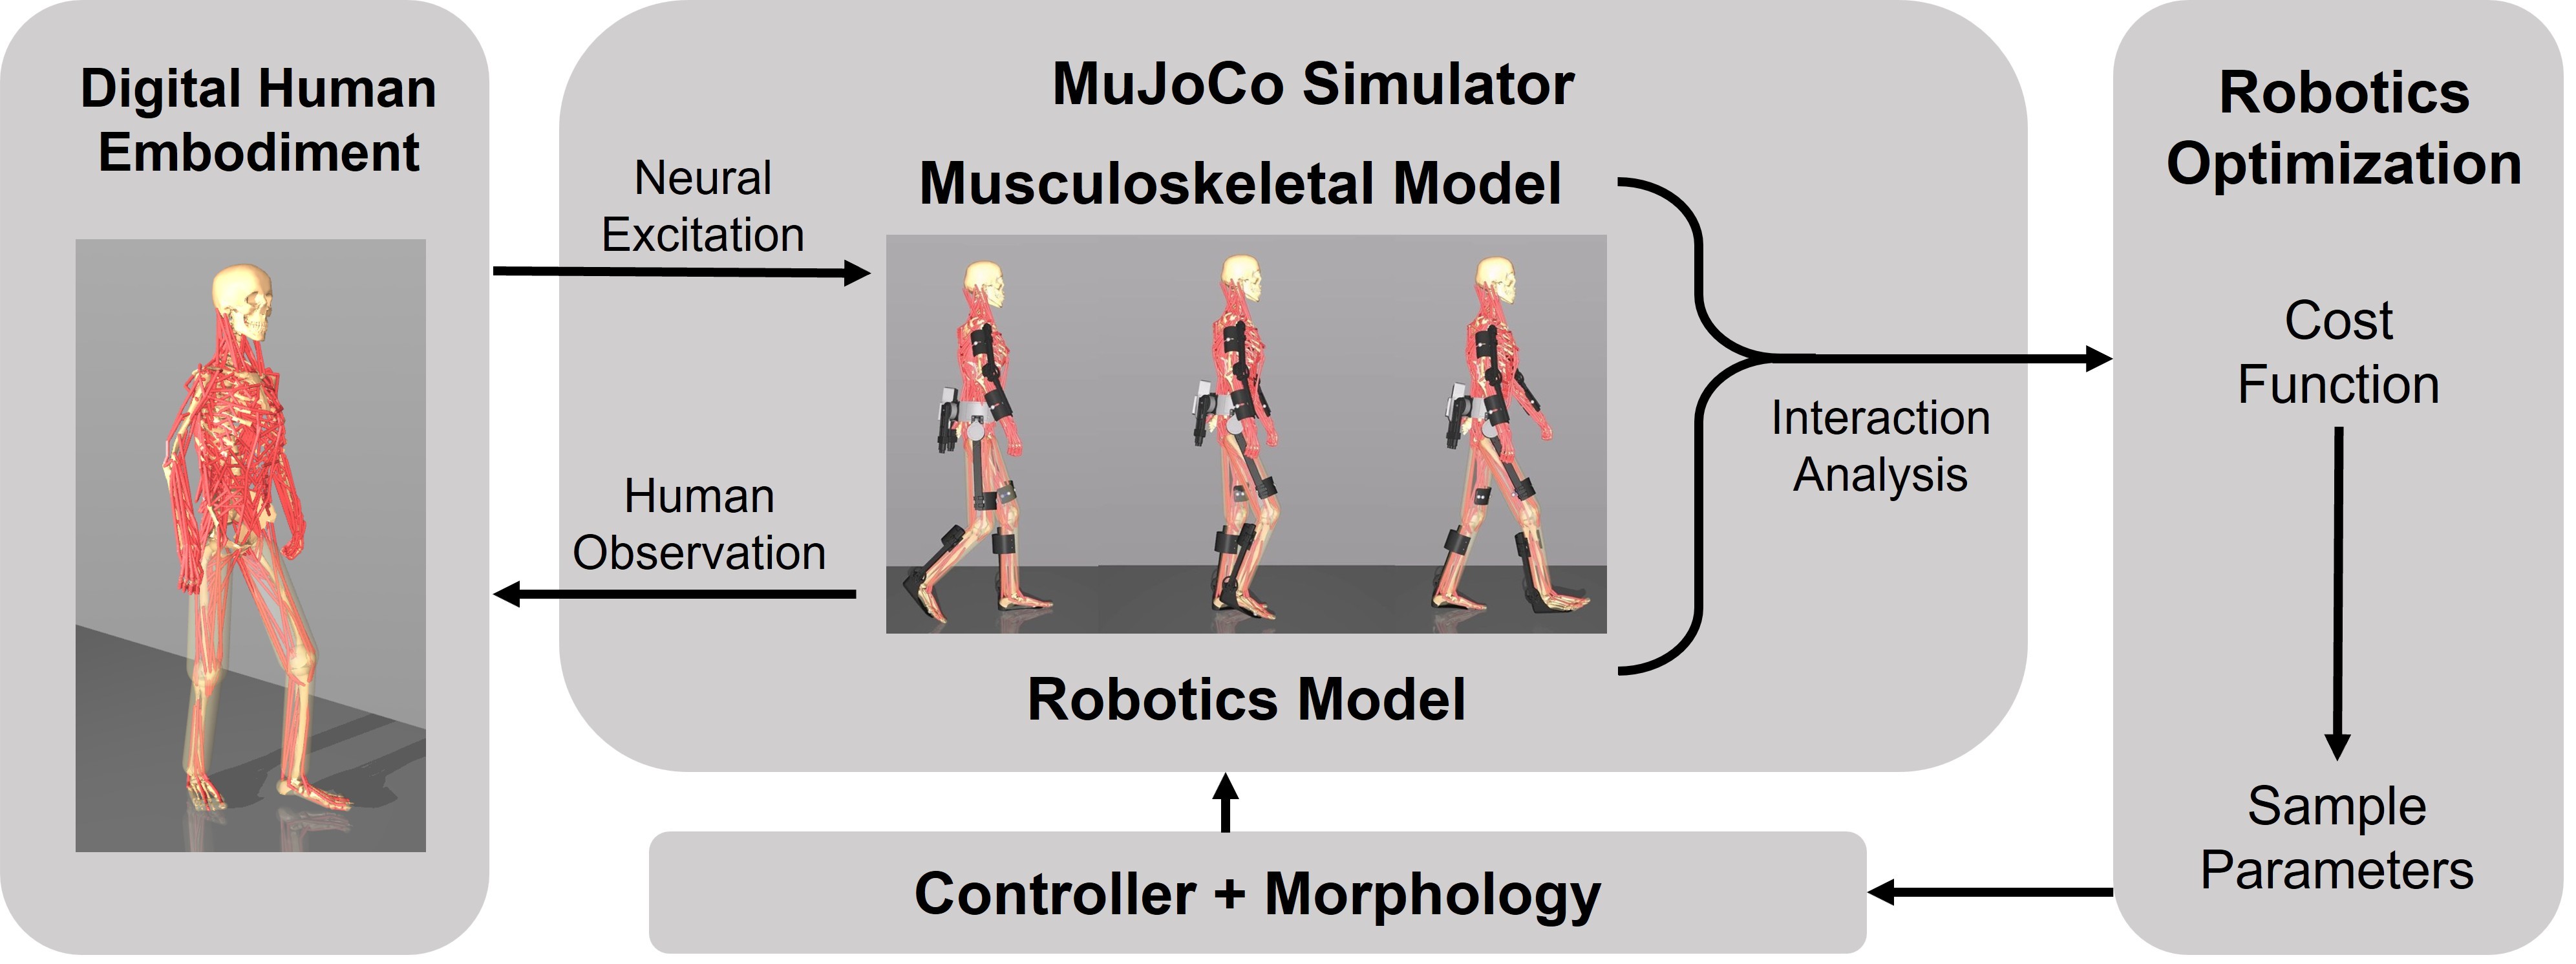
The co-optimization pipeline applied to a wearable exoskeleton, the human policy is trained and applied to robotics optimization.
Demonstrations of the coupled human-robot model with interactive simulation framework.
The co-optimization pipeline applied to a wearable exoskeleton, the human policy is trained and applied to robotics optimization.
The framework's scalability to diverse interactive robotics, illustrated by a human-humanoid collaborative table-carrying task.
Physical interactive robotics, ranging from wearable devices to collaborative humanoid robots, require close coordination between mechanical design and control. However, evaluating interactive dynamics is challenging due to complex human biomechanics and motor responses. Traditional experiments rely on indirect metrics without measuring human internal states, such as muscle forces or joint loads. To address this issue, we develop a scalable simulation-based framework for the quantitative analysis of physical human-robot interaction. At its core is a full-body musculoskeletal model serving as a predictive surrogate for the human dynamical system. Driven by a reinforcement learning controller, it generates adaptive, biomechanically constrained motor behaviors for interaction analysis. We employ a sequential training pipeline where the pre-trained human motion control policy acts as a consistent evaluator, making large-scale design space exploration computationally tractable. By simulating the coupled human-robot system, the framework provides access to internal biomechanical metrics, offering a systematic way to jointly optimize robot structural and control parameters. We demonstrate its capability in optimizing human-exoskeleton interactions, showing improved joint alignment and reduced contact forces. This work establishes embodied human simulation as a scalable paradigm for interactive robotics design.
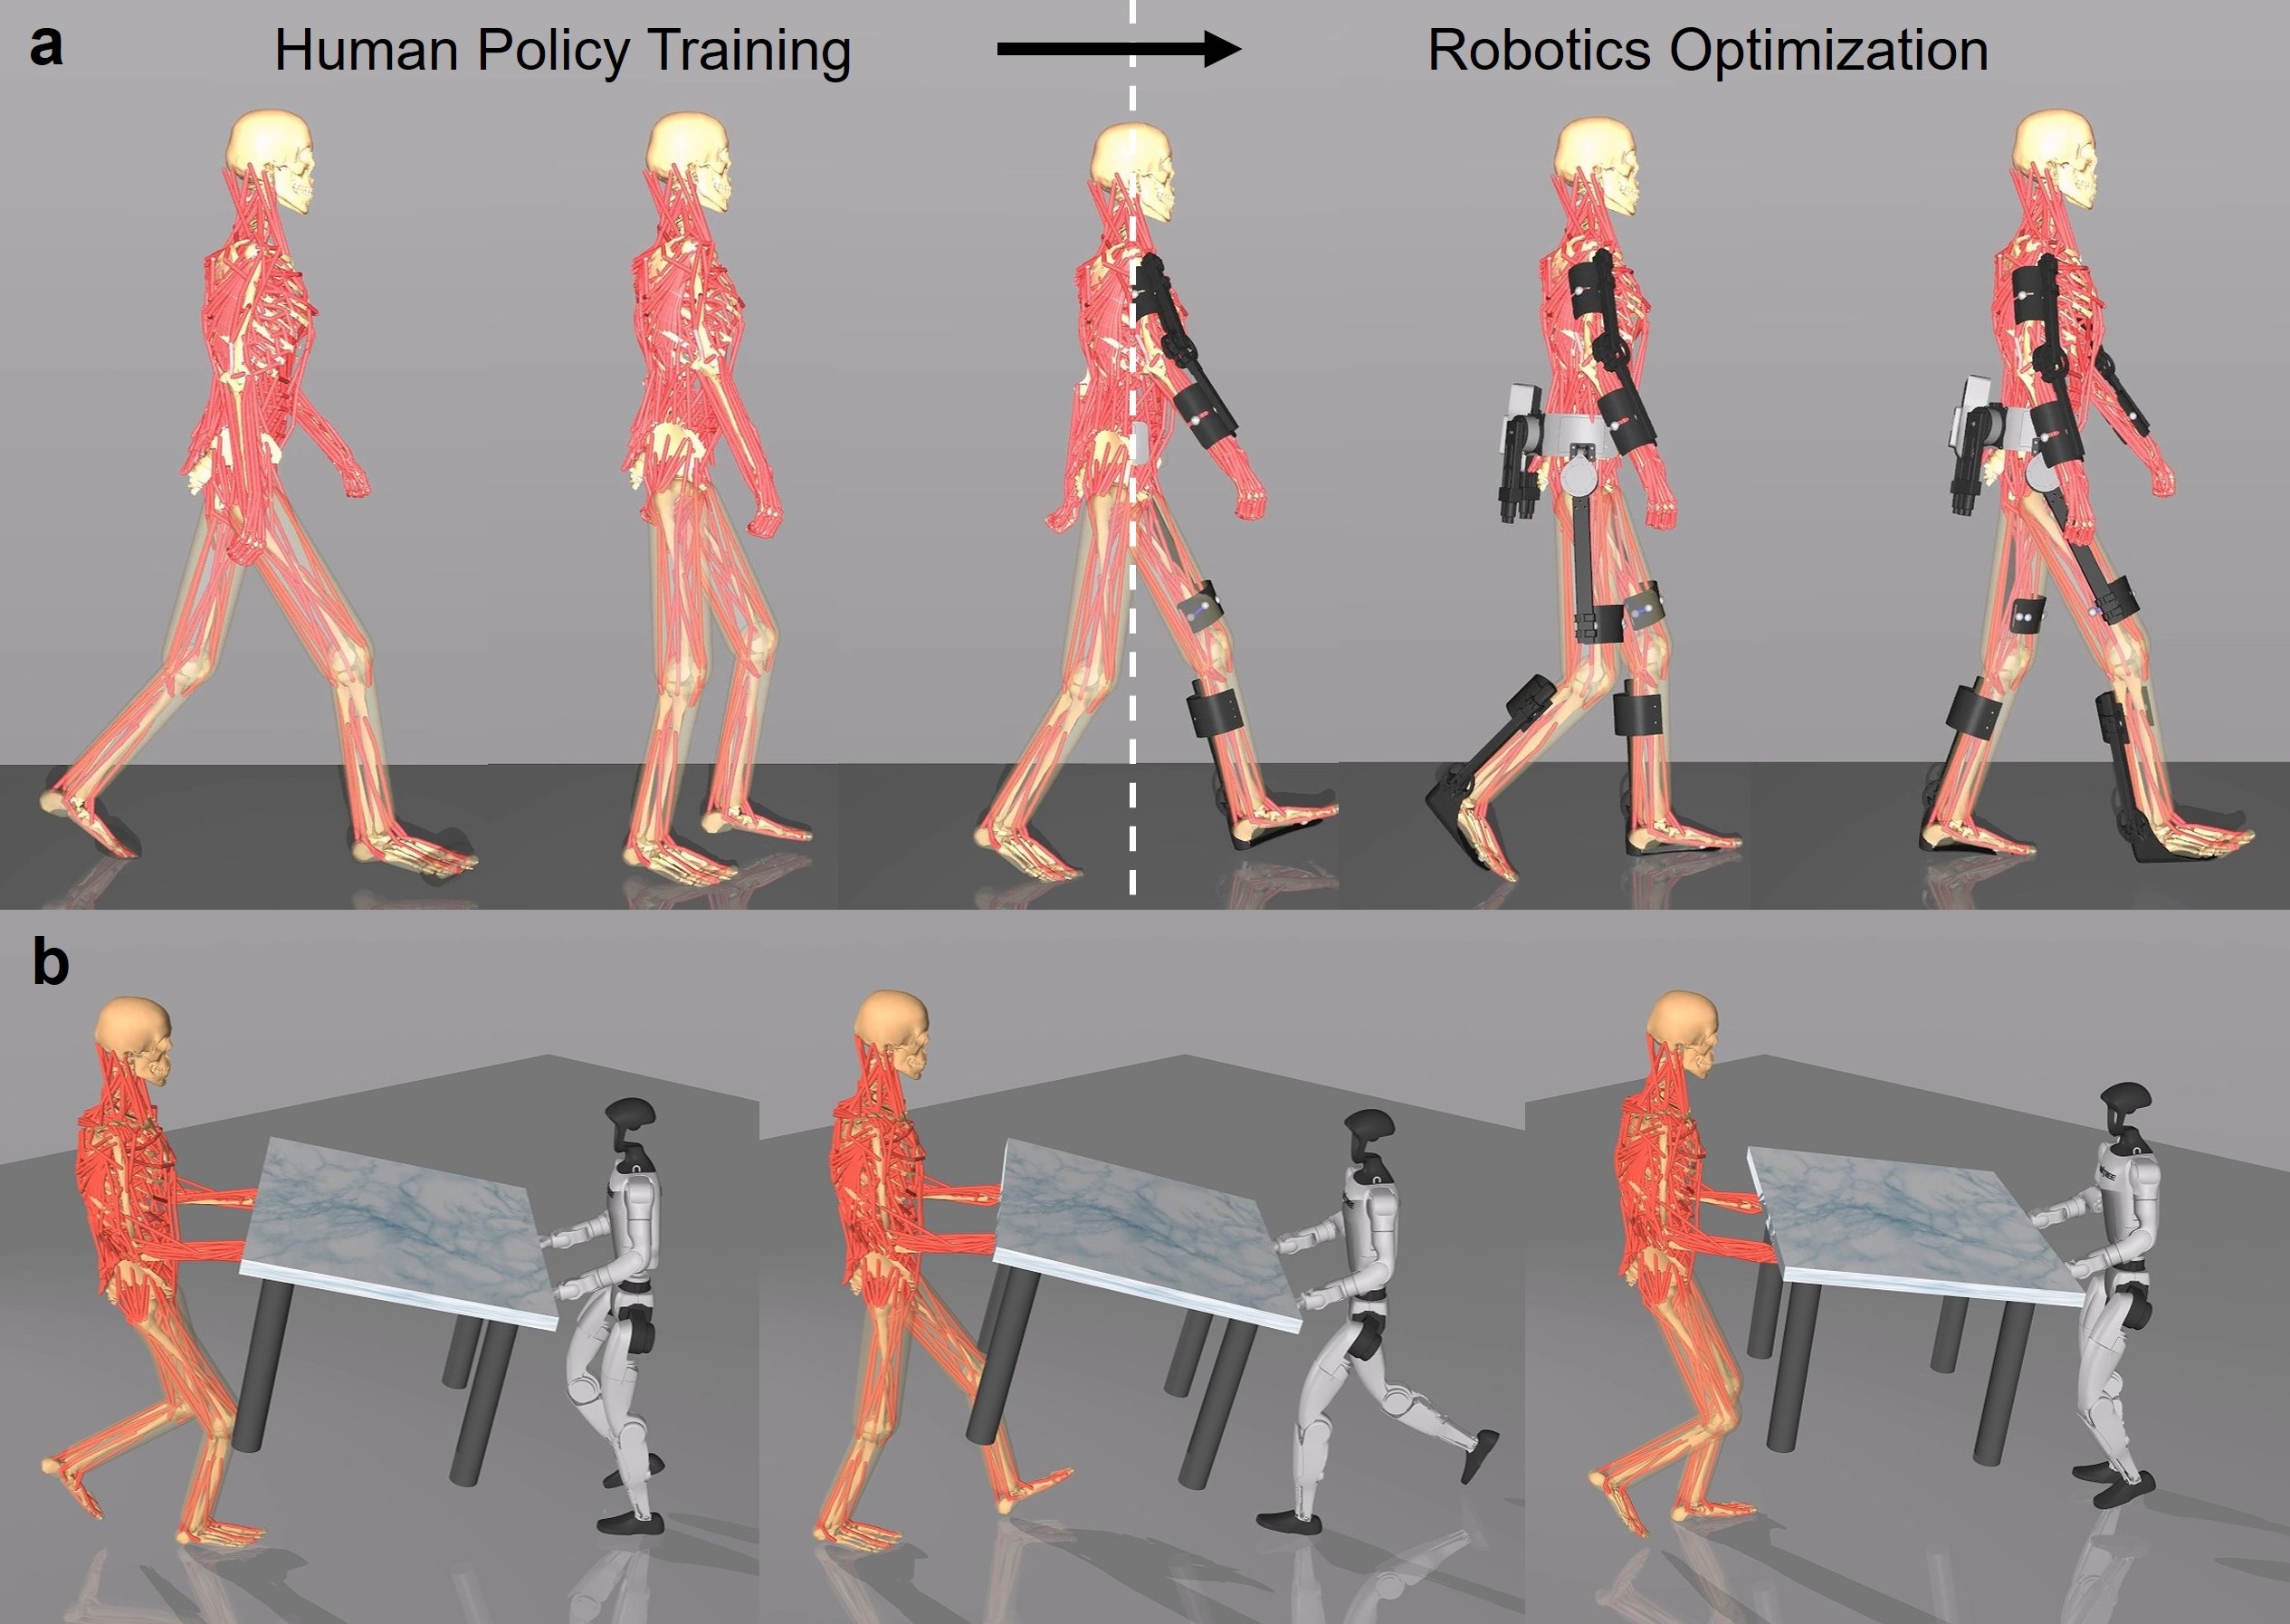
Figure 1. Demonstrations of the Digital Human Embodiment with interactive simulation framework. (a) The co-optimization pipeline applied to a wearable exoskeleton, the human policy is trained and applied to robotics optimization. (b) The framework's scalability to diverse interactive robotics, illustrated by a daily collaborative task with a humanoid robot.
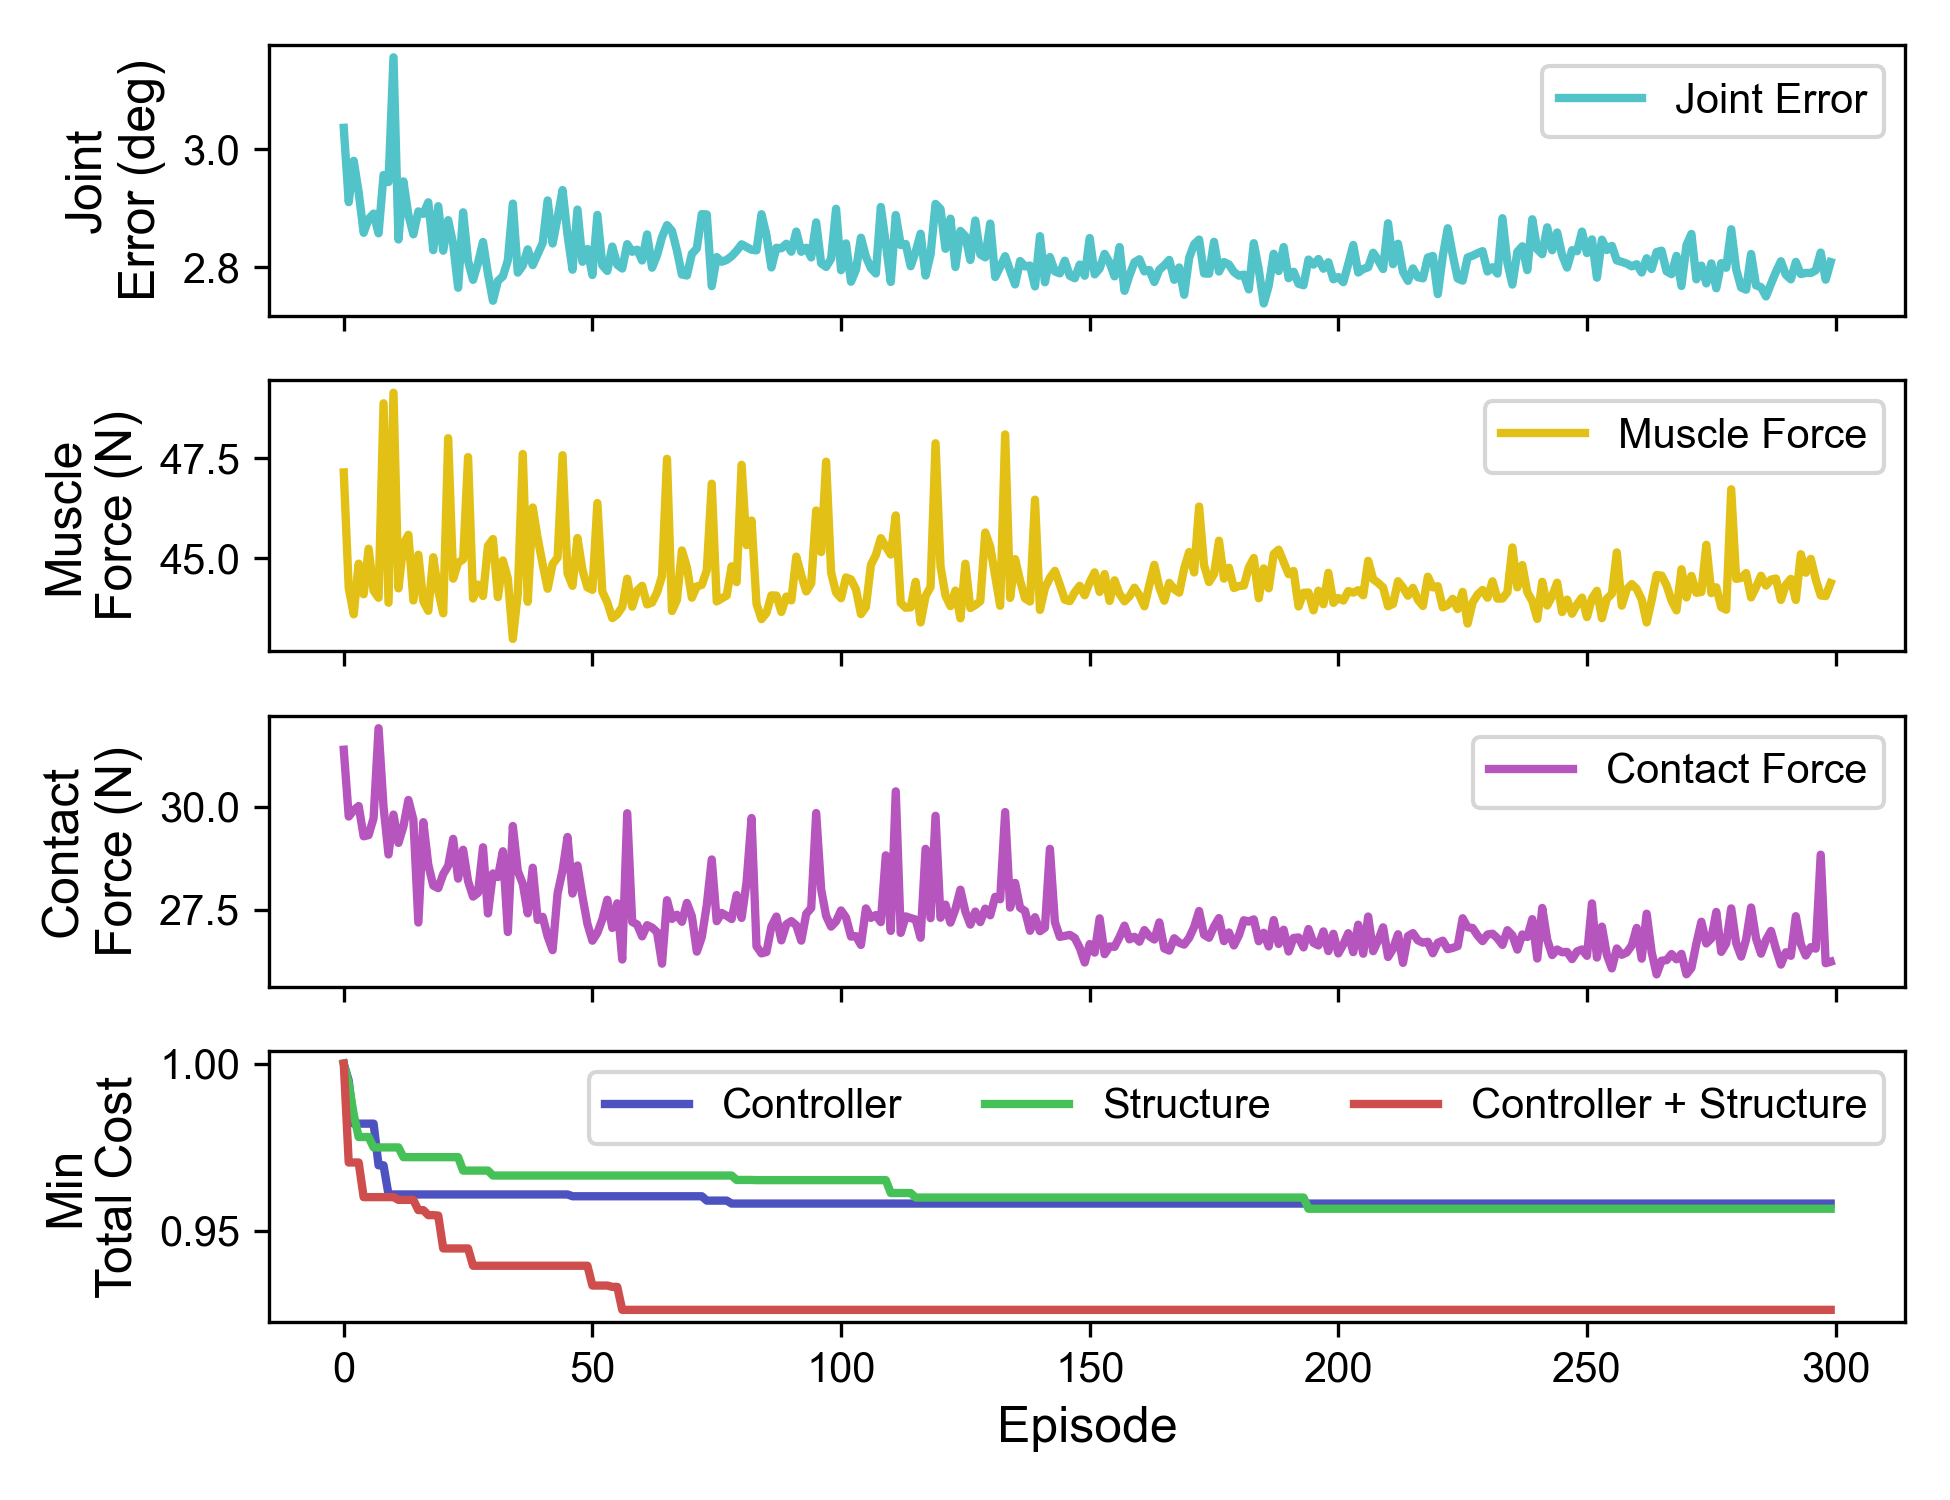
A pretrained human motor policy evaluates each robot design in a coupled MuJoCo simulation. The measured interaction cost is returned to the optimizer, which proposes the next combination of controller gains and structural parameters.
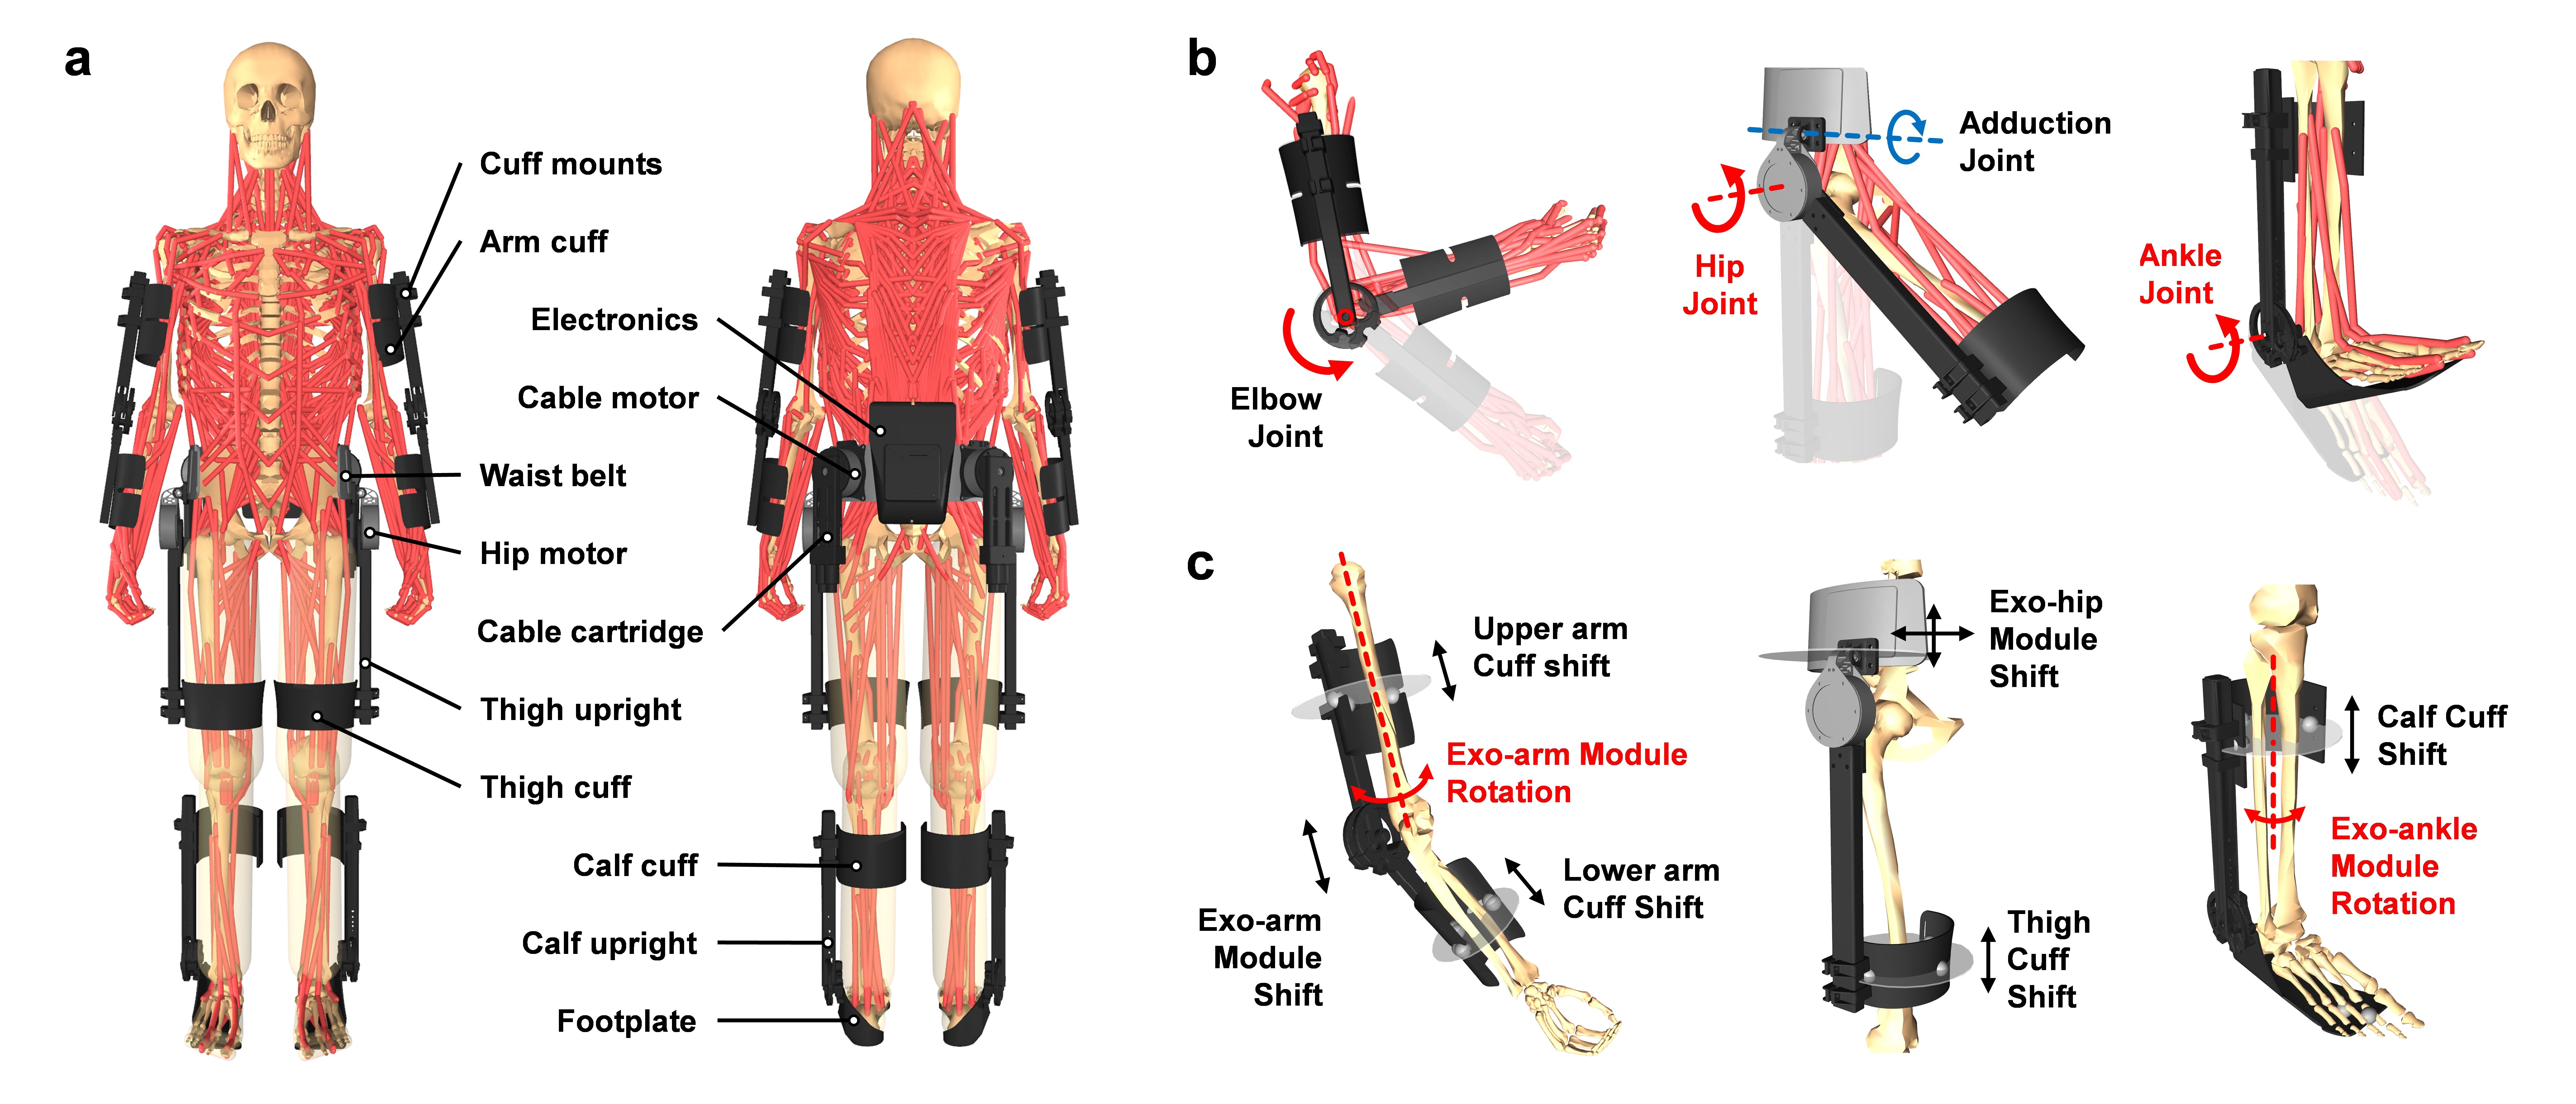
The digital human must reproduce the intended motion and remain responsive to external interaction. We validate both its walking fidelity and its ability to recover from unexpected forces.
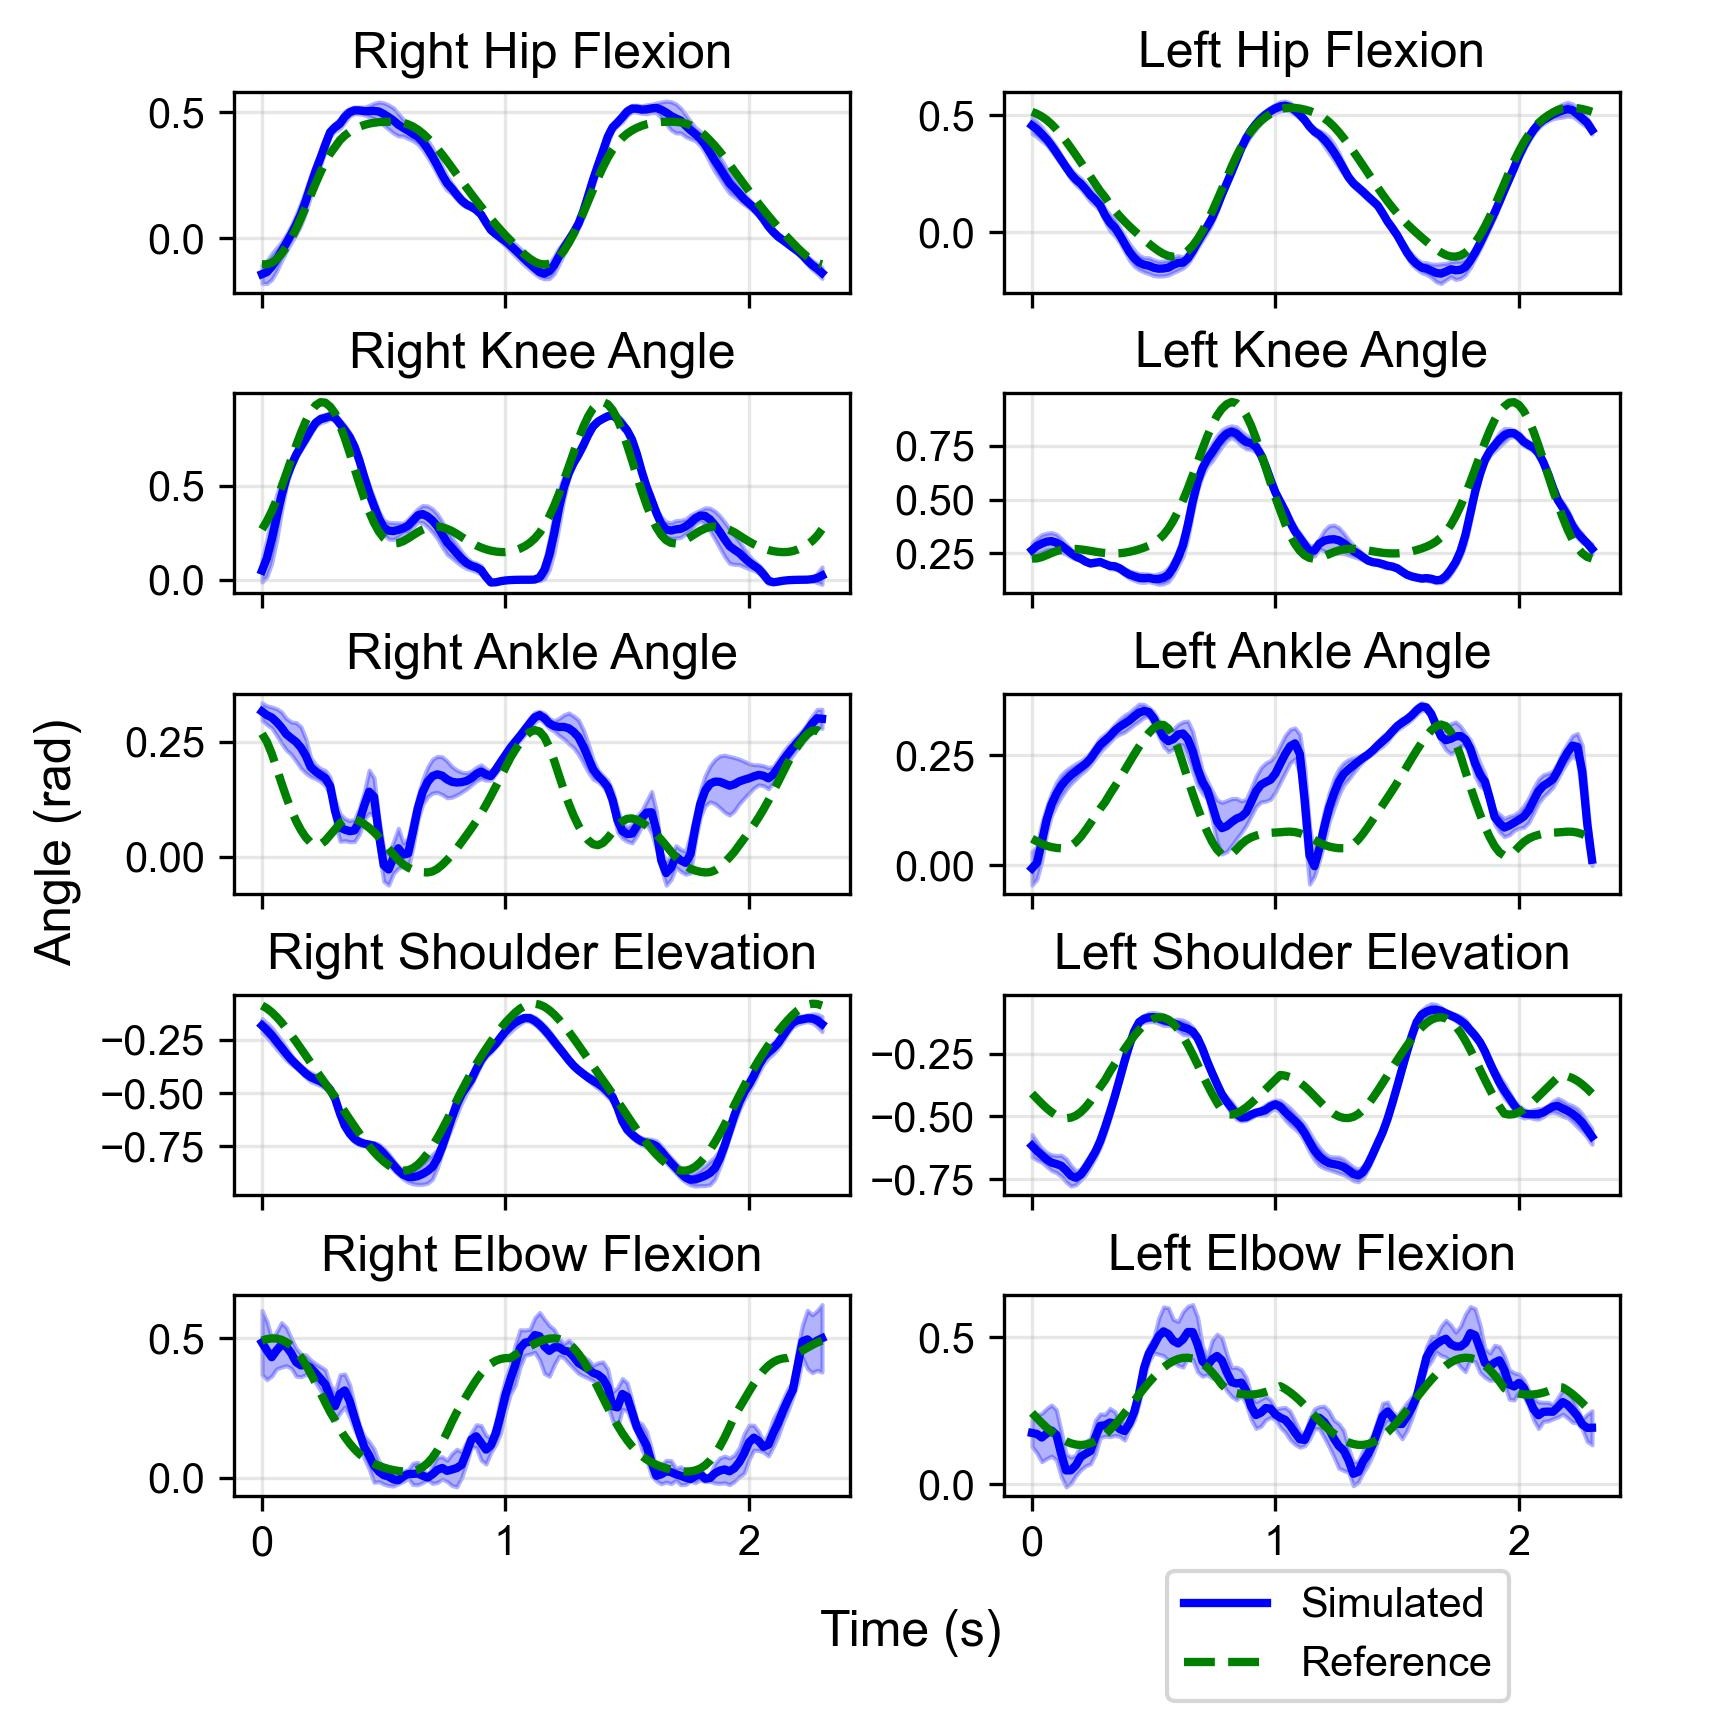
The learned full-body musculoskeletal policy tracks the walking motion evaluated in Figure 4.
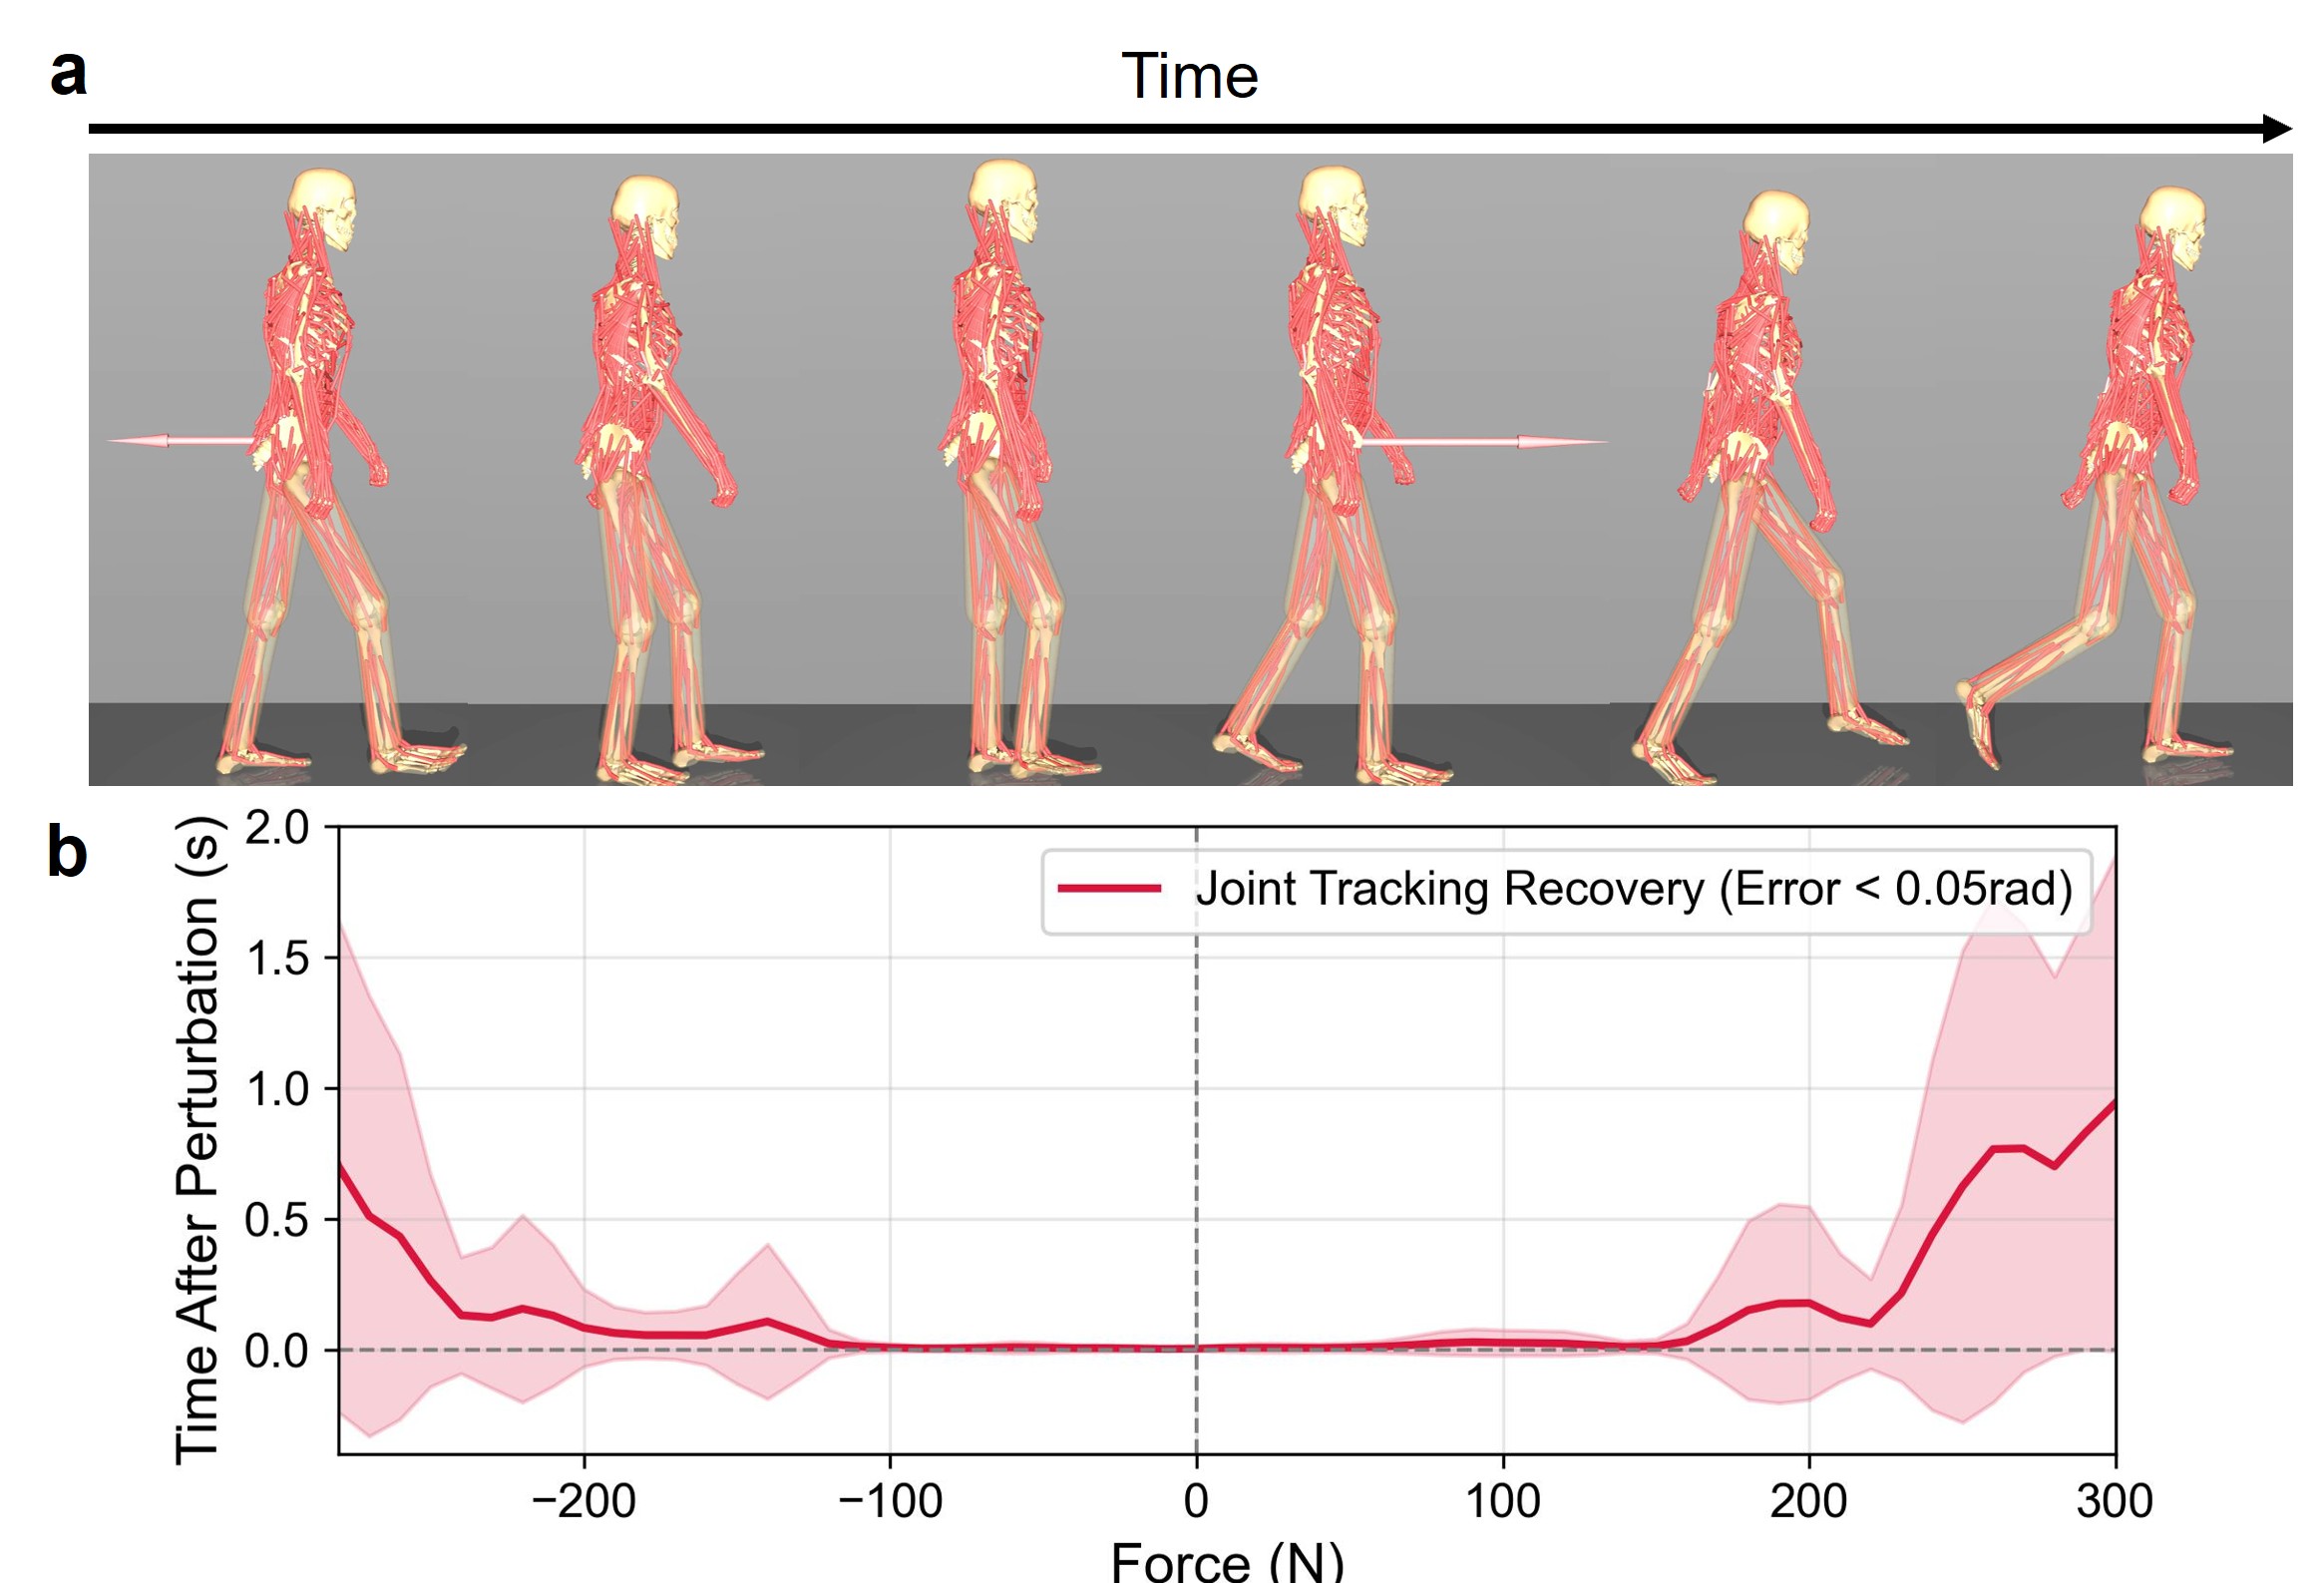
The learned human policy restores balance and gait after the perturbations analyzed in Figure 5.
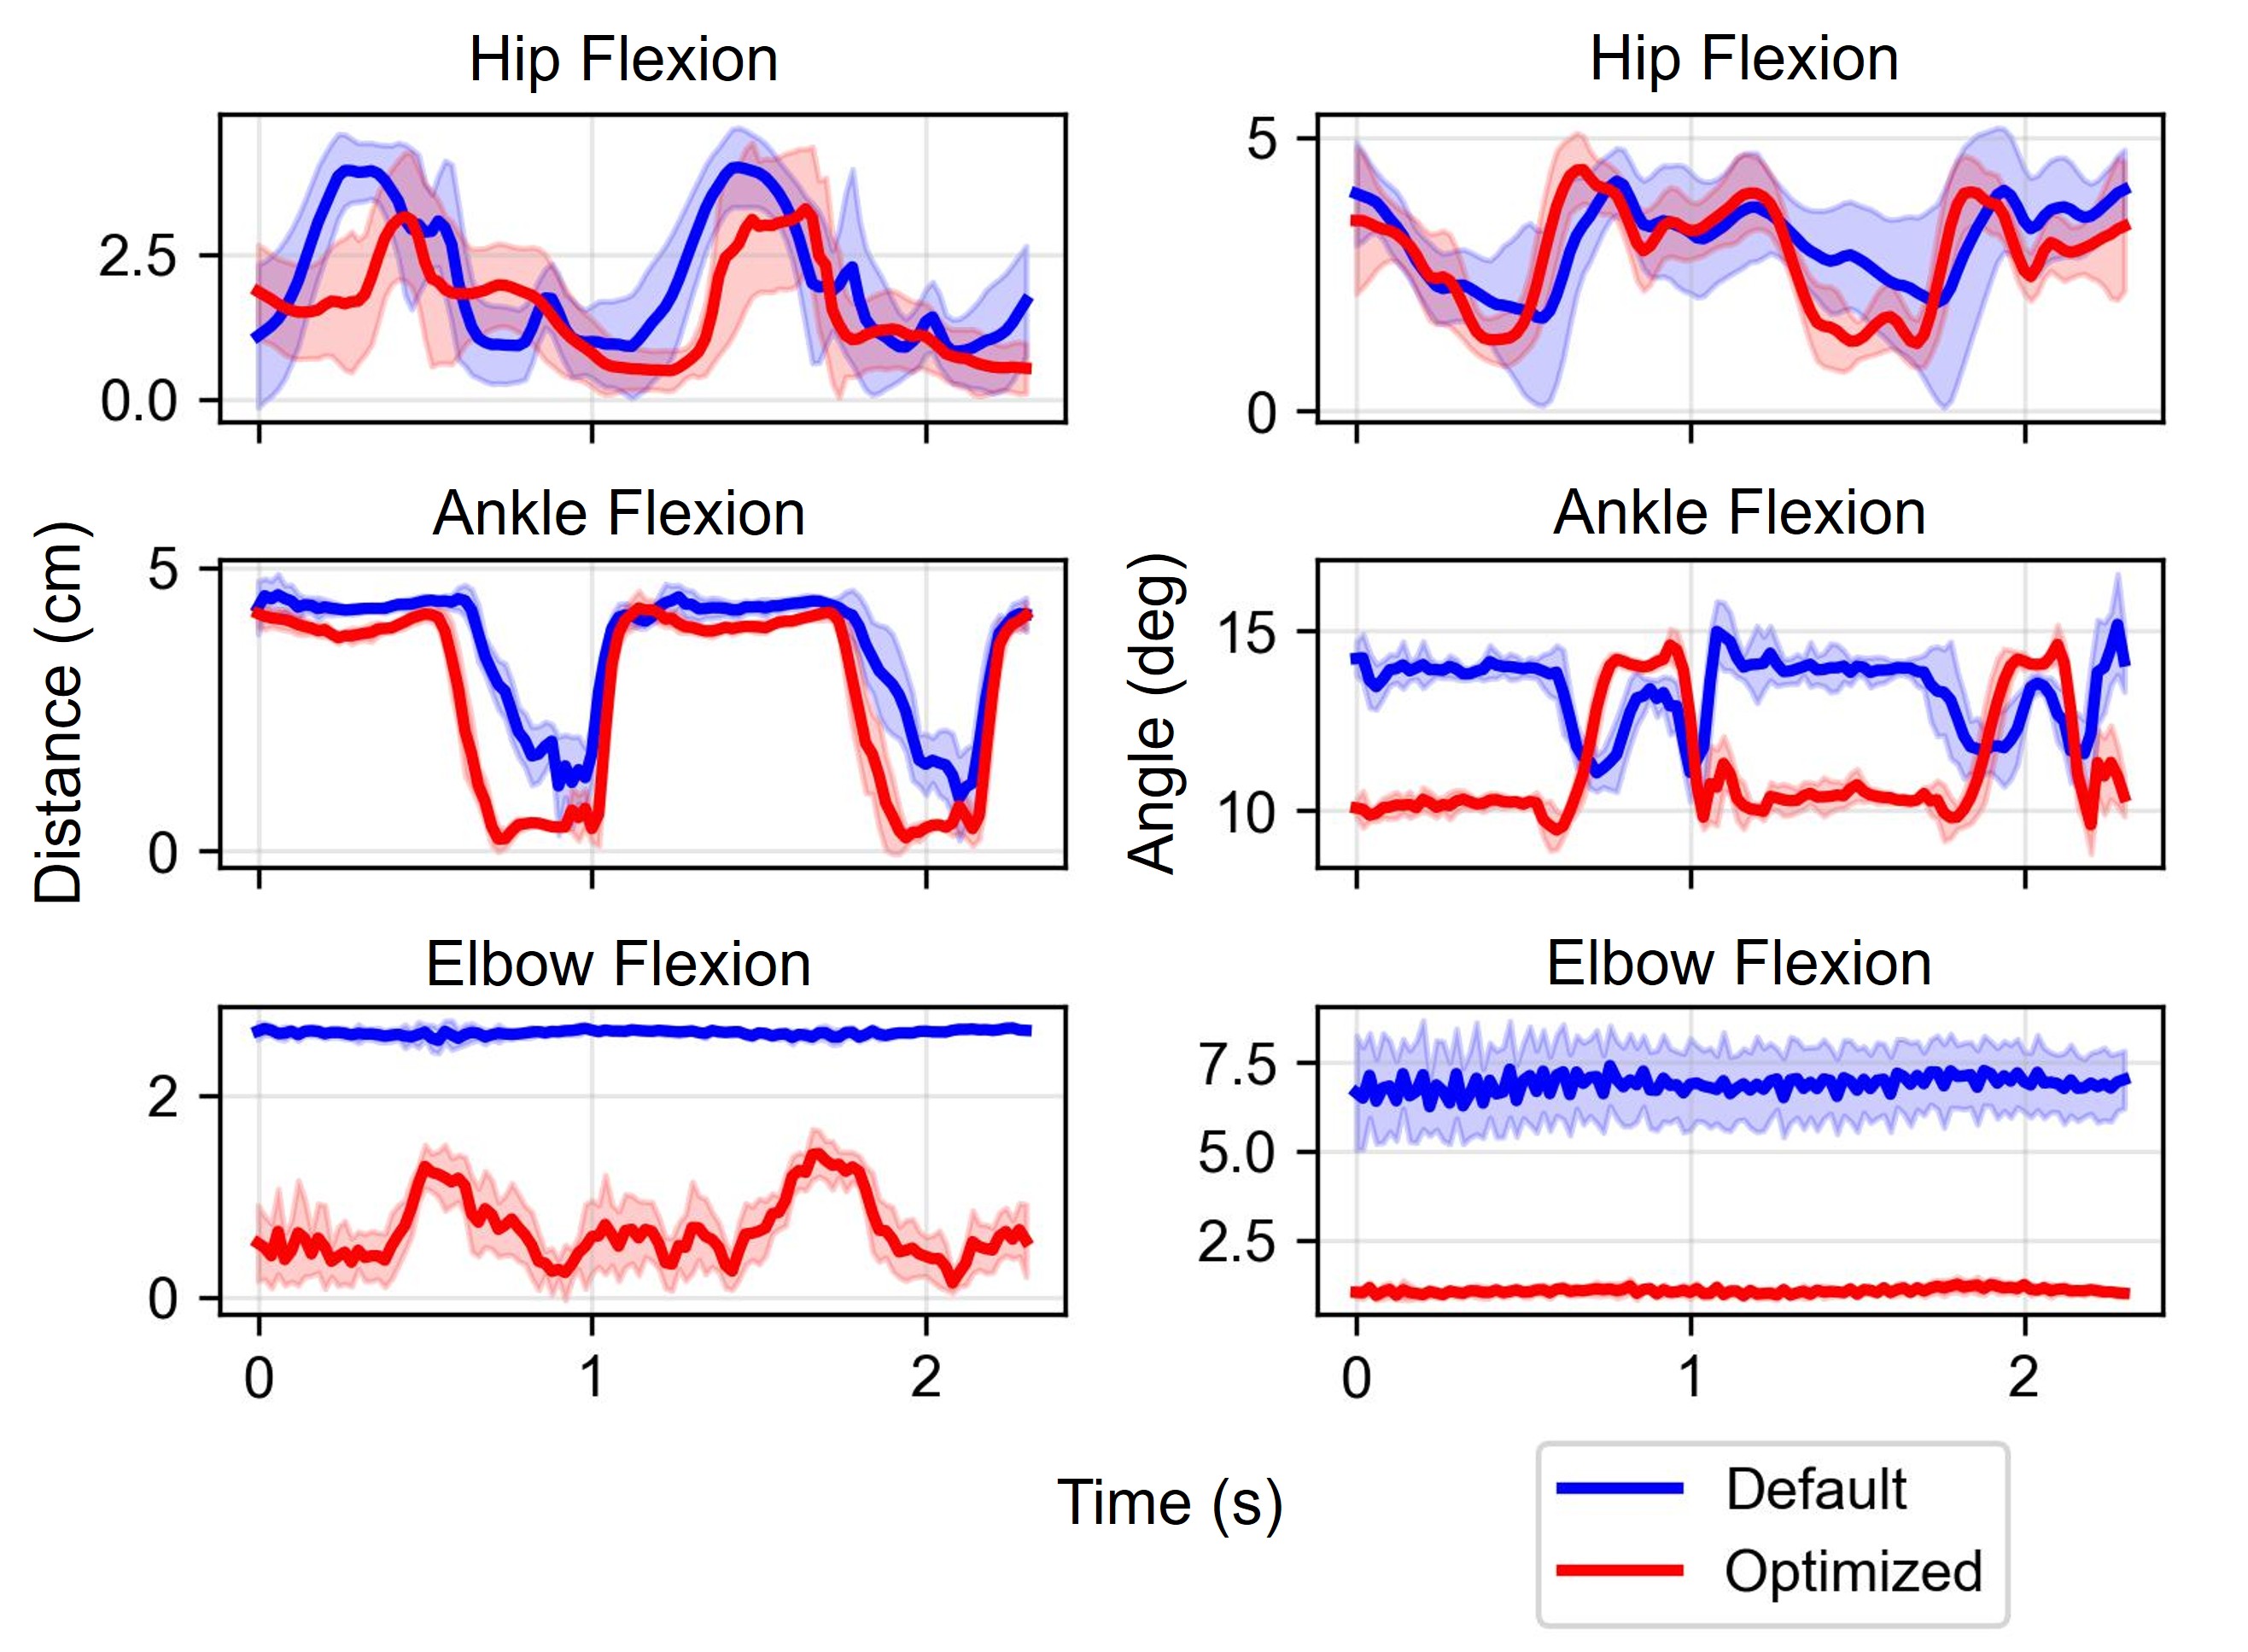
The exoskeleton case study shows why control and physical structure should be designed together. Joint optimization improves the overall interaction objective and produces better alignment between robotic and biological joints.